Essentia / Devices / Surgical Robot
Device Lab 1
Surgical Robot
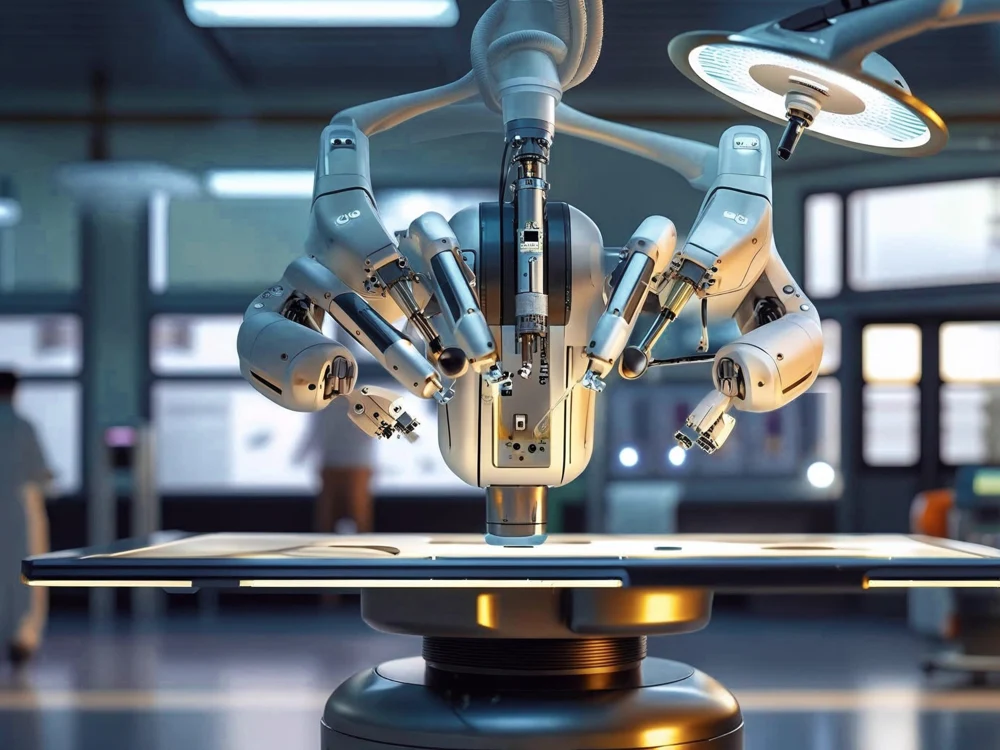
The console is an operator workstation, not an autonomous decision maker. Find the viewing interface, hand controls and foot controls as separate inputs and outputs.
Also called: Robotic Surgery System, Da Vinci. Arabic: الروبوت الجراحي. Device Lab 1 of 69 in BMEssentia Medical City, 3 configurations.
How it works: the main parts
What each part does, from the Surgical Robot lessons in the 3D Device Lab.
- Viewing interface
- A viewing interface turns the imaging chain into information the operator can use. The enclosed viewer and the open-console display are visibly different arrangements in this lab.
- Master hand controls
- The hand controls represent an input to the robot controller. The important relationship is between operator movement, the selected control mapping and instrument response.
- Foot controls
- Several functions may be assigned to foot controls in a real surgical system. Their shape and location are not enough to identify those functions across products.
- System tower
- The tower makes the distributed system visible. Its enclosure contains representative processing and power roles and supports a team display.
- Team display and status interface
- The bedside team needs a shared view of system status. The display in this lab reports the teaching state, input command and illustrative response.
- Controller and processing electronics
- The controller receives inputs and coordinates the represented drive response. It sits between a command and an actuator; it is not a guarantee that the physical system followed the command.
- Power conversion and distribution
- Power is a path through the system, not a single reassuring lamp. This schematic assembly represents the role of supplying usable electrical energy to processing and actuation.
- System connections and communication
- Follow the visible cables between console, tower and patient-side equipment. They make the distributed control problem tangible.
Common faults and what to check
Most reported device problems (FDA MAUDE)
| Device problem | Reports |
|---|---|
| Material Split, Cut or Torn | 45,300 |
| Break | 14,753 |
| Material Frayed | 11,158 |
| Material Fragmentation | 8,099 |
| Visual Prompts will not Clear | 7,325 |
| Detachment of Device or Device Component | 7,132 |
Raw counts of adverse event reports for this device type (FDA product code NAY), all years. Not adjusted for the number of units in use, so they show what gets reported, not failure rates. Report text is never copied.
Planned maintenance checks
From the BMEssentia procedure library: every 6 months, about 240 minutes, electrical class I, applied part type BF.
Preventive maintenance and instrument life are the manufacturer's (service contract). These are the hospital's checks around them.
| Check | Pass when |
|---|---|
| Arms, drapes interface, cables and carts Inspect the arms, sterile adaptor interfaces, the system cables between carts and the console controls. | No damage; cables seated. |
| Electrical safety Test each cart to IEC 62353, and the connected electrosurgical unit. | PE ≤ 0.30 Ω; equipment leakage ≤ 500 µA; applied part BF ≤ 5000 µA. |
| System check and backup Run the manufacturer's system check; confirm the patient cart battery backup and the emergency instrument release. | Check passes; backup and release work as trained. |
| Records Review instrument use counts and the manufacturer's PM report. | No instrument beyond its count; PM current. |
Test instruments: Electrical safety analyser; The manufacturer's system check.
Recent FDA recalls
| Recall | Product and reason |
|---|---|
| Z-2722-2026 2026-07-10 | Intuitive Surgical, Inc.: da Vinci SP Instrument Arm Drape, SP, 1-PACK, Part Number: 430013-13, 430013-15 Robotic-assisted surgical system arm drapes may detach from the instrument arm due to an issue involving the drape rings located at the top of the product, which may expose a section of instrument arm, which may result. Root cause: Process control. |
| Z-2521-2026 2026-06-22 | Intuitive Surgical, Inc.: Da Vinci ASSY, PSS, SP1098, Part Number: 380601 Operative components of surgical systems potentially distributed with E-brake retainer pin, so in event of a structural column failure, the E-brake pin would prevent E-brake engagement and may result in uncontrolled. Root cause: Process control. |
| Z-2310-2026 2026-06-04 | Intuitive Surgical, Inc.: Brand Name: Da Vinci 5 Due to unintentionally activated near infrared handheld camera when attempting to turn off illumination during normal clinical workflow transitions, particularly when switching from the handheld camera to the robotic. Root cause: Device Design. |
| Z-2046-2026 2026-05-01 | Intuitive Surgical, Inc.: Brand Name: Da Vinci X and Da Vinci Xi Due to manipulator containing screws with in the arm sub-assembly that my be susceptible to breaking. Root cause: Nonconforming Material/Component. |
| Z-1855-2026 2026-05-01 | Intuitive Surgical, Inc.: Intuitive 8 mm SureForm 30 Gray Reloads Reloads for curved-tipped stapler may potentially produce an incomplete staple line. Root cause: Under Investigation by firm. |
From the FDA recall database (openFDA), newest first, imported 2026-10-22. 248 recalls on record for this device type. Recall text is the FDA's public text; each recall links to the official record.
Learn it, see it in 3D, ask about it
- Ask Essentia about the Surgical Robot: answers from named sources, with the device open in its 3D Device Lab beside the answer.
- The Surgical Robot on the BMEssentia Platform: the Device Library course, 13 sections from physics to maintenance.
- BMEssentia Medical City: Device Lab 1, the Surgical Robot fully assembled in 3D, with lab tasks and the simulations.
Next: MRI. All 69 devices.
Ask about the Surgical Robot
Sign in with your BMEssentia account, or create one, and ask anything about this device.
Ask Essentia